1:45
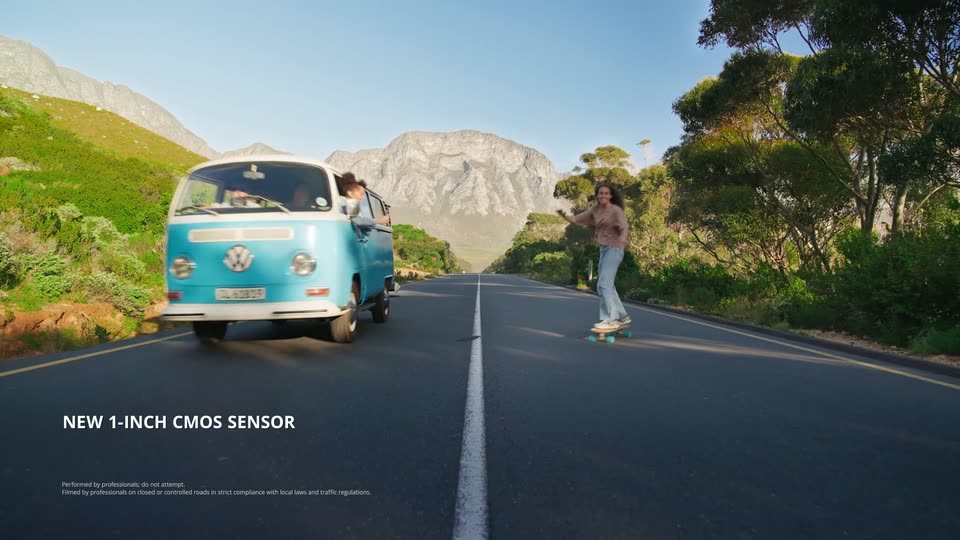
DJI Osmo Pocket 4 is here—redefining what a pocket camera can do.
DJI · Hardware · Apr 2026
Robbyant · Nov 2026 · 1:36 · AI-annotated
Robbyant’s 1:36 launch film runs 35 scenes, about 2.8 s each. The product is on screen from the first frame and 7 features are revealed. There is no explicit call to action; a voiceover carries the film. The video is built as a series of named task blocks, each opened by a white title card over a gray studio still life and followed by locked-off lab footage of the dual-arm rig cut to macro close-ups with fingertip force readouts. Live action and clean 3D renders alternate, with split-screen comparisons and rotating card carousels bridging segments, all held in a bright, high-key, low-contrast palette at a steady 92 bpm pace.
Is this your launch? to your site or press kit.
DJI · Hardware · Apr 2026
A silver robotic hand descends over a white tabletop of everyday objects, presses the rolled brown towel on a wooden bench, then lifts away as the camera pushes in. The set blurs and the title fades in over the padlock.
On-screen text: “Lingbot-Touch”, “Tactile Foundation Model Towards Dexterous Manipulation”
Techniques: 3D mockup
Camera: Push in
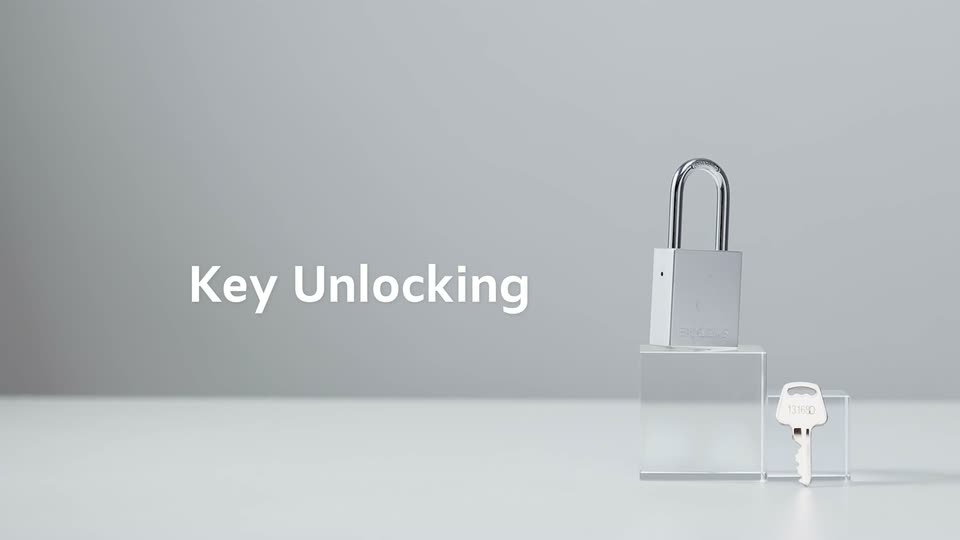
A silver padlock on a white pedestal and a key on a block sit in a gray studio as the title fades in, then the shot cuts to two white robotic arms with blue rings, one gripping the padlock, the other the key, over a workbench.
On-screen text: “Lingbot-Touch”, “Tactile Foundation Model Towards Dexterous Manipulation”, “Key Unlocking”
Camera: Static
Two white robotic arms on a central stand face each other over a white table. The right hand holds a U-shaped metal clip as the left hand's fingers reach in and insert into it. A large 'Key Unlocking' title holds while small captions swap in the bottom right.
On-screen text: “Key Unlocking”, “Sharpa Wave - Visuotactile Tactile Sensor”, “1X Speed, Fully Autonomous Operation”, “Tactile Guidance for Real-time Correction”
Camera: Static
A macro 3D shot of a silver robotic hand articulates its fingers over a blurred white set. A top-left panel plots thumb and index fingertip force, and a small inset video shows the full two-arm rig. A white caption sits in the bottom right corner.
On-screen text: “Tactile Guidance for Real-time Correction”, “1X Speed, Fully Autonomous Operation”
Techniques: 3D mockup
Camera: Static
Two white robot hands work on a small metal carabiner against a soft-focus lab background. The left hand holds a tiny screw near a stamped plate while the right hand grips the clip. A telemetry panel and a wide-angle inset window overlay the footage, with a speed caption in the corner.
On-screen text: “Contact Area Estimation”, “Thumb”, “GT”, “Prediction”, “Fingertip Force Recovery”, “1X Speed, Fully Autonomous Operation”, “Index”
Camera: Static
Two white robotic arms with thin blue rings hover over a white table in a softly blurred room, their hands gripping a small metal tool. The arms shift slightly as they work, while a black stand and two cabinets sit out of focus behind them.
On-screen text: “1X Speed, Fully Autonomous Operation”
Techniques: 3D mockup
Camera: Static
Low-angle shot at table level of two white robotic arms over an open magazine. The left hand grips the page corner, lifts it and flips it, while the right hand hovers and shifts slightly. White captions sit in the lower-right corner.
On-screen text: “XHand1 - Magnetic Tactile Sensor”, “1X Speed, Fully Autonomous Operation”, “Real-world Deployment Across 26 Diverse Tasks”
Camera: Static
A white and black robotic hand hovers over an open magazine on a white table in a bright room, its fingers flexing as it reaches for the page. A low close-up angle with shallow depth of field holds the hand in focus while the background blurs, drifting slightly right.
On-screen text: “Real-world Deployment Across 26 Diverse Tasks”, “2X Speed, Fully Autonomous Operation”
Camera: Push in
A white robotic arm with a segmented gripper holds a clear spray bottle and mists a small green plant in a white pot. The shot is a steady close-up with shallow depth of field in a bright lab, while a caption holds in the lower right corner.
On-screen text: “Spanning Force Control, Deformation”, “1X Speed, Fully Autonomous Operation”, “Real-world Deployment Across 26 Diverse Tasks”
Camera: Static
A white robotic arm with a silver hand lowers a black straw into a red plastic cup of pink liquid on a white table; a white paper cup sits to the right. The arm descends, pushing the straw through the lid. High angle, soft light, shallow depth of field.
On-screen text: “Spanning Force Control, Deformation”, “1X Speed, Fully Autonomous Operation”
Camera: Pull out
A white robotic hand hovers over a black mesh cup and opens its fingers, releasing a blue marker that drops toward the cup. A second robotic arm sits blurred in the background. White captions name the task at the bottom right.
On-screen text: “1X Speed, Fully Autonomous Operation”, “Bimanual Coordination and Visual Occlusion”, “Spanning Force Control, Deformation”
Camera: Static
A silver robotic hand holds a mahjong tile with a green tree above a white table set with three plates of stacked tiles. A small rounded inset in the lower left shows a close-up of a gripper holding a yellow tile. The hand drifts slightly as the camera holds still.
On-screen text: “Bimanual Coordination and Visual Occlusion”, “1X Speed, Fully Autonomous Operation”
Techniques: Split screen
Camera: Static
A split screen shows two close-ups of a gray robotic hand handling mahjong tiles on white plates. Left, the hand presses a blue-marked tile onto a stack; right, it lifts a red-marked tile above the plate. White captions sit at the lower right.
On-screen text: “Bimanual Coordination and Visual Occlusion”, “1X Speed, Fully Autonomous Operation”
Techniques: Split screen
Camera: Static
A white robotic hand presses a small black tab on a dark gray module resting on a white table, then lifts away. A second hand hovers at right beside a clear flat case. A white caption sits in the lower right corner.
On-screen text: “Unified Heterogeneous Tactile Modeling”, “1X Speed, Fully Autonomous Operation”
Camera: Pull out
Split screen: a silver dexterous hand drops a black battery into a power strip on the left, a white two-finger gripper stacks blue cups on the right. The two panels then curl into a 3D cylinder as a caption appears below.
On-screen text: “1X Speed, Fully Autonomous Operation”, “Unified Heterogeneous Tactile Modeling”, “R”
Techniques: Split screen, Morph
Camera: Push in
White rounded cards in 3D perspective rotate one step at a time, bringing each rendered haptic sensor to the front: a copper dimpled pad, a gray sensor with a glowing orange tip, a black magnet. A white headline below changes between two lines, then fades.
On-screen text: “Enabling Seamless Multi-sensor Integration”, “And Reuse of Tactile Representations”
Techniques: 3D mockup
Camera: Static
A curved 3D carousel of white rounded cards, each holding a robotic hand with a model name below, scrolls left so the highlighted center card moves from Revo 3 to Sharpa Wave. A white headline sits static at the bottom.
On-screen text: “Cross-platform Dexterous Hand Compatibility”
Techniques: 3D mockup, Parallax
Camera: Static
A locked-off studio shot on a gray seamless backdrop: a black electric toothbrush head with a rose gold cap rests on a clear acrylic block beside an upright white toothpaste tube with purple labeling. The white caption Toothpaste Dispensing holds center-left, static.
On-screen text: “Cross-platform Dexterous Hand Compatibility”, “Toothpaste Dispensing”
Camera: Static
Locked-off wide shot on a gray studio set: a white multi-arm robot lowers its right hand to grasp a black toothbrush on a wooden holder, the left hand hovering over a cup with a purple toothpaste tube, as the right arm lifts and tilts the brush.
On-screen text: “Toothpaste Dispensing”, “1X Speed, Fully Autonomous Operation”
Camera: Static
A split screen shows a silver robotic arm lowering a purple tube into a white cup on the left, while the right holds a close-up of a robotic hand gripping a black toothbrush. A small inset in the lower left frames the full two-arm rig.
On-screen text: “1X Speed, Fully Autonomous Operation”
Techniques: Split screen
Camera: Static
Split screen: left, a silver robotic hand squeezes a purple toothpaste tube into a white cup, with a small wide-shot inset below; right, a close-up of a hand gripping a black electric toothbrush. A HUD panel with two force graphs labeled Thumb and Index appears top left.
On-screen text: “1X Speed, Fully Autonomous Operation”, “Thumb”, “Index”
Techniques: Split screen
Camera: Static
Split screen: left, a silver robotic hand holds a toothbrush above a white cup, with a fingertip force panel top-left and a small inset of the full rig; right, a close-up of the hand gripping the black toothbrush while a bottle hovers above.
On-screen text: “1X Speed, Fully Autonomous Operation”
Techniques: Split screen
Camera: Static
A macro shot of a silver robotic hand squeezes a purple and white toothpaste tube, the tube bulging between its fingers. A data card with two force charts and a small inset of the full arm sit in the corners, while a white caption names the action.
On-screen text: “Future Force Prediction”, “Thumb”, “Index”, “Fingertip Force Recovery”, “Precise Force Control for Deformable Objects”, “1X Speed, Fully Autonomous Operation”
Camera: Pull out
A silver robotic hand grips a toothbrush loaded with purple toothpaste and squeezes it, while a small wide-angle inset replays the arm from the front. A force-prediction chart panel sits top left; white captions read at the bottom right. The hand shifts slightly as it compresses the paste.
On-screen text: “Future Force Prediction”, “Precise Force Control for Deformable Objects”, “1X Speed, Fully Autonomous Operation”
Camera: Static
A locked-off studio shot frames two white robotic arms on a central mount above a table. The right arm uses a small brush on a white cup on a wooden stand, while the left arm holds a tool. A pole-mounted camera sits behind the arms against a blurred gray set.
On-screen text: “1X Speed, Fully Autonomous Operation”, “Precise Force Control for Deformable Objects”, “Future Force Prediction”
Camera: Static
A clear water bottle stands on a white surface against a gray backdrop, its black cap resting on a clear acrylic cube. The white title Cap Unscrewing fades in at left; the frame stays locked and static.
On-screen text: “Cap Unscrewing”, “1X Speed, Fully Autonomous Operation”
Camera: Static
Two white robotic arms with articulated hands face each other against a plain gray studio wall. The left hand holds a black cap, the right a clear water bottle, twisting the cap off slowly. A camera on a tripod stands between them in a locked-off wide shot.
On-screen text: “Cap Unscrewing”, “1X Speed, Fully Autonomous Operation”
Camera: Static
Locked-off close-up of polished silver robot fingers gripping and turning the black cap of a clear plastic bottle. A force-recovery HUD sits top-left and a small inset shows the full two-arm lab rig. The fingers rotate the cap, then open and pull away.
On-screen text: “Multi-Finger Coordination”, “1X Speed, Fully Autonomous Operation”
Camera: Static
Two silver robotic arms with articulated hands hold a clear plastic bottle in a bright white studio. The left hand opens and lifts away while the right hand keeps its grip, a slow, smooth hand-off. A tripod camera and dark shelving sit in the soft-focus background.
On-screen text: “Smooth Manipulation · No Contact Loss · No Slip”, “1X Speed, Fully Autonomous Operation”, “Multi-Finger Coordination”, “Index”, “Thumb”
Camera: Static
A yellow stand-up pouch with a clear window showing coffee beans stands on a clear disc, a second flat pouch lies in front, against a gray backdrop. The white title Bag Sealing holds still on the left in a locked-off frame.
On-screen text: “Bag Sealing”
Camera: Static
Two silver robotic arms hover over a white table. The left hand lowers onto the open top of a brown coffee pouch while the right hand pinches the pouch's upper edge to seal it. A glass dish of coffee grounds rests at right. The camera stays locked off.
On-screen text: “Bag Sealing”, “1X Speed, Fully Autonomous Operation”
Camera: Static
Two silver robotic hands grip the open top of a brown paper bag in a 3D render, fingers adjusting as they hold it. A small wide-angle inset sits in the lower left and a fingertip-force panel fades in at the upper left.
On-screen text: “Fine-Grained Tactile Perception”, “1X Speed, Fully Autonomous Operation”, “Thumb”, “Index”
Techniques: 3D mockup
Camera: Static
Close-up 3D render of a silver robotic hand pinching a thin orange paper strip, then releasing it as it bends and dangles. Shallow depth of field blurs the foreground finger. Force-recovery graphs overlay top-left, a wide context shot of the robot sits bottom-left, a caption anchors bottom-right.
On-screen text: “Continuous Seal-line Contact”, “1X Speed, Fully Autonomous Operation”, “Fine-Grained Tactile Perception”
Techniques: 3D mockup
Camera: Static
Two silver robotic hands grip the top seal of a brown paper bag, then the left hand releases and lifts away while the right holds it. A force-reading panel sits top-left and a small wide-angle inset shows the full table setup bottom-left.
On-screen text: “1X Speed, Fully Autonomous Operation”, “Continuous Seal-line Contact”
Camera: Push in
A 3D white studio set with acrylic blocks, a wooden frame, a plant and a vase sits on a table. The white Robbyant wordmark starts oversized and out of focus, then scales down to a centered logo as the camera pulls back and the set sharpens.
On-screen text: “Robbyant”
Techniques: Kinetic type
Camera: Pull out